Distributed tactile contact mapping
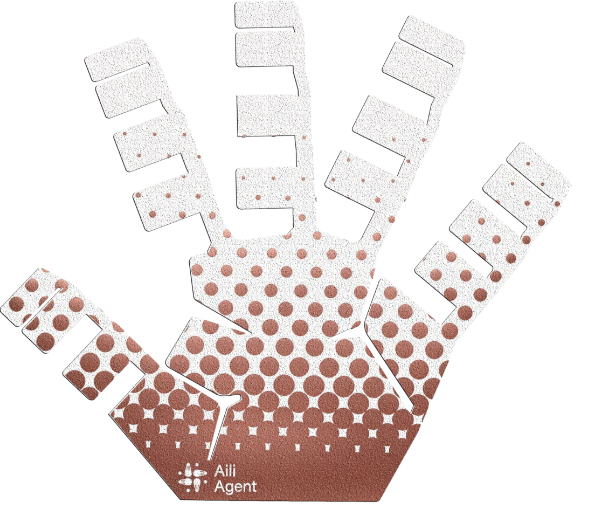
HTact-ileskin Motus™ Flexible Tactile Skin (Palm)
A high-density tactile skin designed for robotic palms, with 634 sensing points at a density of 9/cm² for fingertip-level pressure-distribution sensing. It resolves contact shape, edges and slip tendency when grasping fragile or small objects, delivering millisecond-level tactile feedback for dexterous manipulation — a key sensing layer for precision work by service robots and bionic hands.
- Sensing axes
- 1 DOF
- Model range
- 300–600 kPa
- Official models
- 4
Dynamic Tactile Pressure Demonstration
A simulated pressure array shows how tactile-distribution data can be organized. The grid is illustrative — values are software-generated, not readings from connected hardware.
- PK
- 0.00 kPa
- AVG
- 0.00 kPa
- AREA
- 0 %
This dashboard uses slowly changing simulated values. No physical sensor is connected.
Core Capabilities
The capability points below are taken from the official product material for this family.
634 sensing points at 9/cm² for fingertip-level pressure-distribution sensing
Resolves contact shape, edges and slip tendency when grasping fragile or small objects
Millisecond-level tactile feedback for dexterous manipulation
Key sensing layer for precision work by service robots and bionic hands
Quick Start
A practical integration sequence; final mechanical and electrical details follow the official technical file.
Select the model
Match the expected load to one of the official variants in this family.
Mount at the measurement point
Confirm the mechanical interface and protect the sensing body from unintended loads.
Connect data acquisition
Connect the specified power and communication interface according to the official technical file.
Zero, verify and acquire
Zero the unloaded sensor, verify channel directions, then use the measured data in the control workflow.
Technical Specifications
| Parameter | Specification |
|---|---|
| Measuring range | 300kPa |
| Sensing points | 634 |
| Point density | 9/cm² |
| Sampling frequency | 200Hz |
| Resolution | 2.5%F.S |
| ADC bit depth | 16-bit |
| Power supply | 8~46V |
| Communication protocol | UDP |
Application Scenarios
Current product content and selection relationships support the following customer tasks.
For tactile contact distribution at skin, sole, hand and teleoperation interfaces.
- APPLICATION 01
Service robots
Distributed tactile contact mapping - APPLICATION 02
Bionic hands
Distributed tactile contact mapping - APPLICATION 03
Fragile / small-object grasping
Distributed tactile contact mapping - APPLICATION 04
Dexterous manipulation
Distributed tactile contact mapping
Applicable Robots and Mounting Locations
Robot types and locations below are generated from the current selection relationships rather than page-specific marketing copy.
Current selection: Humanoid Robots · Distributed tactile contact mapping
- Humanoid Robots
- Teleoperation Interfaces
- Torso
- Arm
- Calf
- Finger
- Palm
- Sole
Select a model
- HTI-T-300-256-U
- Axes
- 1
- Diameter
- —
- Range
- 300
- HTI-L-300-128-U
- Axes
- 1
- Diameter
- —
- Range
- 300
- HTI-P-300-634-U
- Axes
- 1
- Diameter
- —
- Range
- 300
- HTI-F-600-128-U
- Axes
- 1
- Diameter
- —
- Range
- 600
Selected: HTI-L-300-128-U
Downloads
Documents are being prepared. No file is linked until it is official.
Data note
Some parameter information continues to be verified. Refer to the official technical documentation.
Ready to Touch?
Turn every surface of a robot into skin that understands contact.