Rotary-joint torque feedback
JTorq Motus™ Robot Joint Torque Sensor
A torque sensor that measures the output torque of robot motor joint modules, providing real-time data for closed-loop torque control, overload protection and condition monitoring. It offers a multi-range design, low drift, good repeatability and standardized interfaces, and suits integrated joints, servo drives and test platforms.
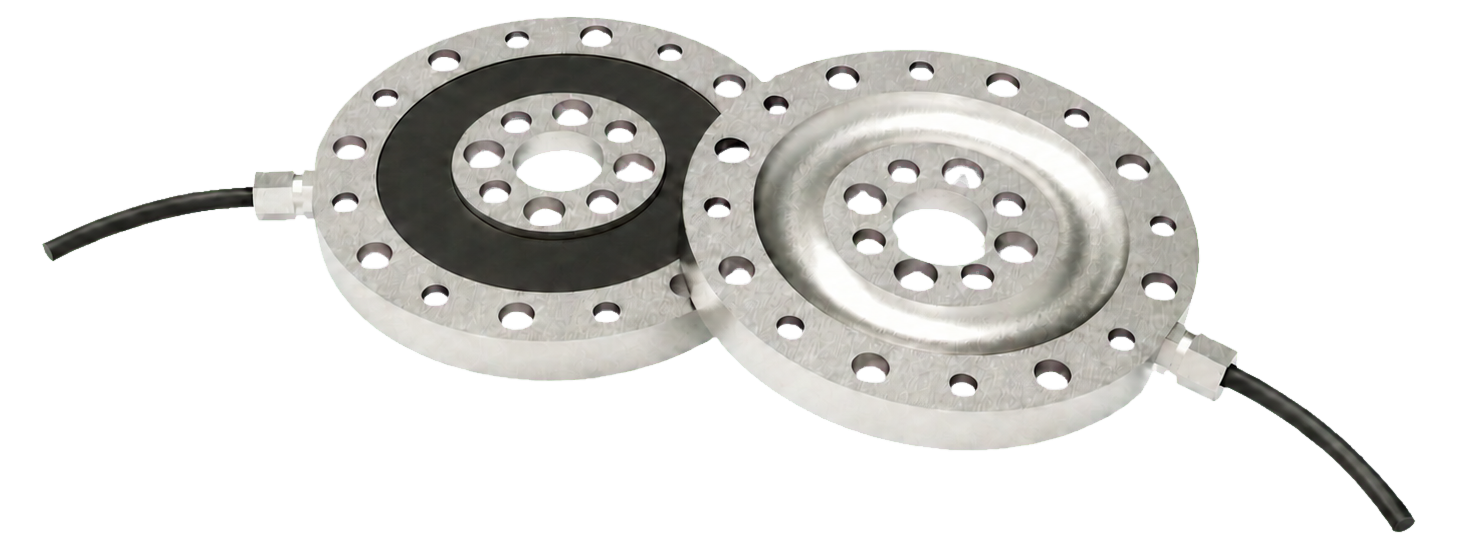
- Force / torque axes
- 1 DOF
- Sensor diameter
- Ø45–135 mm
- Model range
- 5–800 Nm
- Official models
- 12
Dynamic Force / Torque Data Demonstration
A single simulated torque channel shows how joint-loading data can be organized. The values below are software-generated for demonstration, not readings from connected hardware.
- Mz
- 0.00 Nm
- PK
- 0.00 Nm
- RMS
- 0.00 Nm
This dashboard uses slowly changing simulated values. No physical sensor is connected.
Core Capabilities
The capability points below are taken from the official product material for this family.
Real-time output torque measurement for closed-loop torque control, overload protection and condition monitoring
Multi-range design
Low drift and good repeatability
Standardized interfaces
Quick Start
A practical integration sequence; final mechanical and electrical details follow the official technical file.
Select the model
Match the expected load to one of the official variants in this family.
Mount at the measurement point
Confirm the mechanical interface and protect the sensing body from unintended loads.
Connect data acquisition
Connect the specified power and communication interface according to the official technical file.
Zero, verify and acquire
Zero the unloaded sensor, verify channel directions, then use the measured data in the control workflow.
Technical Specifications
| Parameter | Specification |
|---|---|
| Sensor material | Stainless steel |
| Sensor type | Resistive strain gauge |
| Mz range (Nm) | 10~200 (multiple ranges per model: M-D045:10/20/50; M-D065:10/20/50/100/150; M-D085/105/155:50/100/150/200) |
| Overload capacity (%) | 200 |
| Non-linearity (%F.S) | <0.1 |
| Repeatability (%F.S) | <0.2 |
| Hysteresis (%F.S) | <0.5 |
| Temperature drift (%F.S/10°C) | <0.2 |
| Zero drift (%F.S/30min) | <0.1 |
| Input/output impedance | 700±5Ω |
| Insulation resistance | ≥500MΩ (100V DC) |
| Supply voltage | 3.3–15V |
| Operating temperature range | -20–80°C |
Application Scenarios
Current product content and selection relationships support the following customer tasks.
For torque feedback at dexterous, collaborative and industrial joints.
- APPLICATION 01
Integrated joints
Rotary-joint torque feedback - APPLICATION 02
Servo drives
Rotary-joint torque feedback - APPLICATION 03
Test platforms
Rotary-joint torque feedback
Applicable Robots and Mounting Locations
Robot types and locations below are generated from the current selection relationships rather than page-specific marketing copy.
Current selection: Humanoid Robots · Rotary-joint torque feedback
- Humanoid Robots
- Collaborative Robots
- Industrial Robots
- Rotary-joint actuator
Select a model
- M-D45-005
- Axes
- 1
- Diameter
- 45
- Range
- 5
- M-D45-010
- Axes
- 1
- Diameter
- 45
- Range
- 10
- M-D55-015
- Axes
- 1
- Diameter
- 55
- Range
- 15
- M-D55-030
- Axes
- 1
- Diameter
- 55
- Range
- 30
- M-D75-80
- Axes
- 1
- Diameter
- 75
- Range
- 80
- M-D75-150
- Axes
- 1
- Diameter
- 75
- Range
- 150
- M-D95-100
- Axes
- 1
- Diameter
- 95
- Range
- 100
- M-D95-300
- Axes
- 1
- Diameter
- 95
- Range
- 300
- M-D115-200
- Axes
- 1
- Diameter
- 115
- Range
- 200
- M-D115-500
- Axes
- 1
- Diameter
- 115
- Range
- 500
- M-D135-400
- Axes
- 1
- Diameter
- 135
- Range
- 400
- M-D135-800
- Axes
- 1
- Diameter
- 135
- Range
- 800
Downloads
- D65 · STEPDownload STEP
Data note
Some parameter information continues to be verified. Refer to the official technical documentation.
Ready to Drive?
Give every robot joint an exact sense of how hard it is working.